Knowledge
How to Image and Submicron-Position a 0.025 mm Fiber Optic Hole
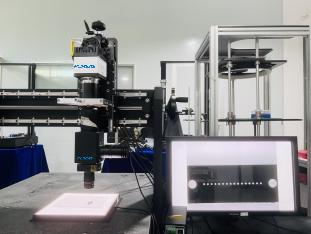
In short: a 0.025 mm diameter hole can be imaged with sharp edges and located repeatably to better than 1 µm by combining three elements: a 65 MP global-shutter industrial camera (3.2 µm pixel), an infinity-corrected, field-corrected optic suitable for apochromatic objectives, and a flat parallel backlight with a half-angle below 0.1°. This application note explains why conventional illumination schemes fail at this scale, how the required resolution is dimensioned, and which configuration was used in the real project.
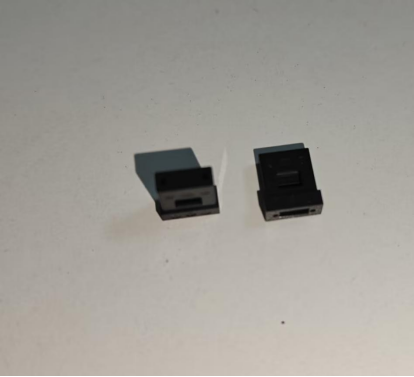
Key project parameters
| Parameter | Value | Source |
|---|---|---|
| Hole diameter | 0.025 mm (25 µm) | Project record |
| Diameter of the fiber to be inserted | 0.020 mm (20 µm) | Project record |
| Required positioning accuracy | ≤ 1 µm | Project record |
| Sensor resolution | 9344 × 7000 px (65 MP) | Official product documentation |
| Pixel size | 3.2 µm | Official product documentation |
| Working field of view | 7 mm | Project record |
| Object-side resolution per pixel (calculated) | ≈ 0.75 µm/px | Own calculation from FOV (estimate) |
Background: why 25 µm is a borderline case
The end user is a fiber optic product manufacturer; the requirement came from the maker of the automatic assembly equipment, which had to insert a 20 µm fiber into a 25 µm hole. The mechanical margin between the two is only 2.5 µm per side, so machine vision cannot afford any drift in estimating the hole center: the full positioning requirement is ≤ 1 µm throughout the insertion operation.
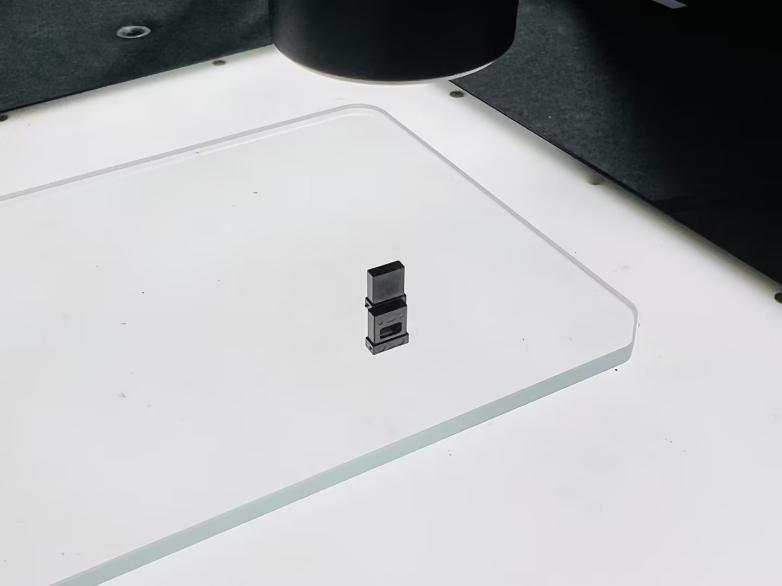
Why conventional schemes fail
Three technical reasons explain why the integrator's earlier trials did not reach the target repeatability:
- Insufficient sampling resolution. With large-pixel, low-resolution cameras the edge of the 25 µm hole is represented by very few pixels and appears blurred; sub-pixel edge extraction loses statistical meaning and repeatability degrades far above 1 µm.
- Illumination with a diffuse component. Conventional ring or area sources produce scattered reflection and edge halo on a translucent plastic part: the measured edge shifts with brightness and position, and the calculated center fluctuates from cycle to cycle.
- Limited installation space. The assembly station must work at a short distance while keeping illumination uniform and contrast high, which rules out bulky optics or long working distances.
System configuration
| Component | Specification used | Source |
|---|---|---|
| Industrial camera | 65 MP global-shutter CMOS, 3.2 µm pixel, 9344 × 7000 px, 10G Ethernet transmission | Official product documentation |
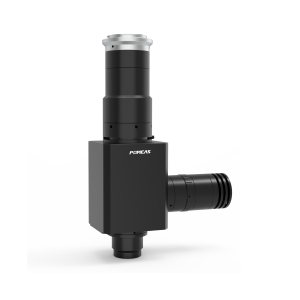
| Optics | HD objective with M58 mount, infinity-corrected optical design, compatible with flat-field apochromatic objectives up to 2", integrated coaxial optical path | Official product documentation |
| Illumination | Flat parallel backlight, parallelism half-angle < 0.1°, uniformity of the useful area > 90 % | Official product documentation |
The calculation that fixes the design
The single figure that decides whether the sensor "sees" the hole is the resolution per pixel projected onto the object:
Resolution per pixel = FOV ÷ horizontal pixels = 7000 µm ÷ 9344 px ≈ 0.75 µm/px (estimate calculated from the documented FOV).
At 0.75 µm per pixel, the 25 µm diameter is sampled with more than 33 pixels and the 2.5 µm margin per side with more than 3 pixels: enough for sub-pixel edge extraction. The global shutter, in turn, removes the "jelly" distortion caused by vibration of the insertion mechanism, so that every image used for the center calculation is undistorted. The parallel backlight with a half-angle < 0.1° is the piece that closes the system: by illuminating almost in collimation, the gray transition at the hole edge is narrow and stable, and the edge centroid no longer depends on brightness or on the position of the part.
Project result
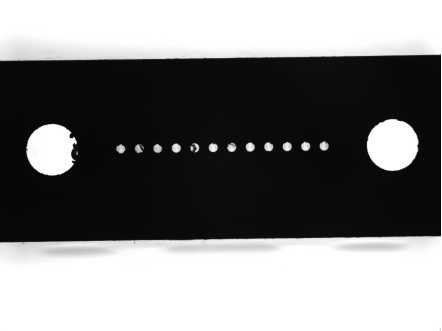
According to the project record, the system imaged the 0.025 mm hole stably with sharp edges and high contrast, and guided the insertion mechanism within the ≤ 1 µm positioning requirement, removing the reject-rate bottleneck that conventional schemes had carried.
Decision chain for your own application
- Smallest feature to measure → dimension the FOV and require at least 3–5 pixels across the critical detail (the usual sampling rule).
- Target resolution per pixel → sensor pixel ÷ system magnification; if it falls short, increase resolution or magnification, do not crop the FOV.
- Edge type → translucent parts or critical edges: parallel backlight (half-angle < 0.1°); opaque surfaces with relief: coaxial or bright-field light.
- Motion or vibration during capture → global shutter is mandatory.
- Available space → check mount and working distance before fixing the optics (here: M58 with objectives up to 2").
Frequently asked questions
The most common questions about this application are answered below; for an evaluation of your specific part, contact our technical team.
Why isn’t a conventional camera enough to position a 0.025 mm hole?
A conventional large-pixel camera leaves the edge of a 25 µm hole represented by very few pixels, so sub-pixel edge extraction loses repeatability. With the documented system (9344 × 7000 px sensor, 3.2 µm pixel and 7 mm field of view), the object-side resolution per pixel is ≈ 0.75 µm (an estimate calculated as FOV ÷ horizontal pixels), i.e. more than 33 pixels across the hole diameter: the minimum sampling basis for positioning below 1 µm.
What does a parallel backlight with a half-angle below 0.1° add compared with a ring or area source?
Conventional sources mix in diffuse light that creates halo and shifts the measured edge with brightness and part position, especially on translucent plastics. The flat parallel backlight illuminates almost in collimation: the gray transition at the edge is narrow and stable (uniformity of the useful area > 90 %), so the calculated hole center no longer depends on the illumination conditions.
Why is a global shutter required on this assembly station?
The insertion mechanism introduces vibration. With a rolling shutter each sensor row is exposed at a different instant and the image distorts (the jelly effect), which deforms the projected circle of the hole and corrupts the center calculation. A global shutter exposes the whole array at the same time and guarantees that every image used for positioning is undistorted.
Can this scheme be replicated on other micromachined parts?
Yes. The decision chain transfers: define the critical feature and the field of view with at least 3–5 pixels of sampling; verify that sensor pixel ÷ system magnification reaches the required resolution per pixel; choose the illumination by edge type (parallel for critical edges on translucent parts); use a global shutter if there is motion; and check mount and working distance against the available space. To evaluate a specific part, provide dimensions, tolerance and sample images to the technical team.
Related products
- POMEAS industrial lenses — infinity-corrected optics and precision objectives.
- Machine vision lighting — flat parallel backlights and area sources.
- Industrial cameras — high-resolution global-shutter sensors.
📖 Also available in: 中文 · Español · Français · Русский · العربية

Subscribe to Our Newsletter
Simply enter your email to receive the latest news and insights from Pomeas. Stay connected with Pomeas and be the first to discover new innovations in optical excellence.


